Diagonals.
On 25th September we decided to see how far we could get round the maze..
See above video for the result. Click here to see the code... and the tuning file
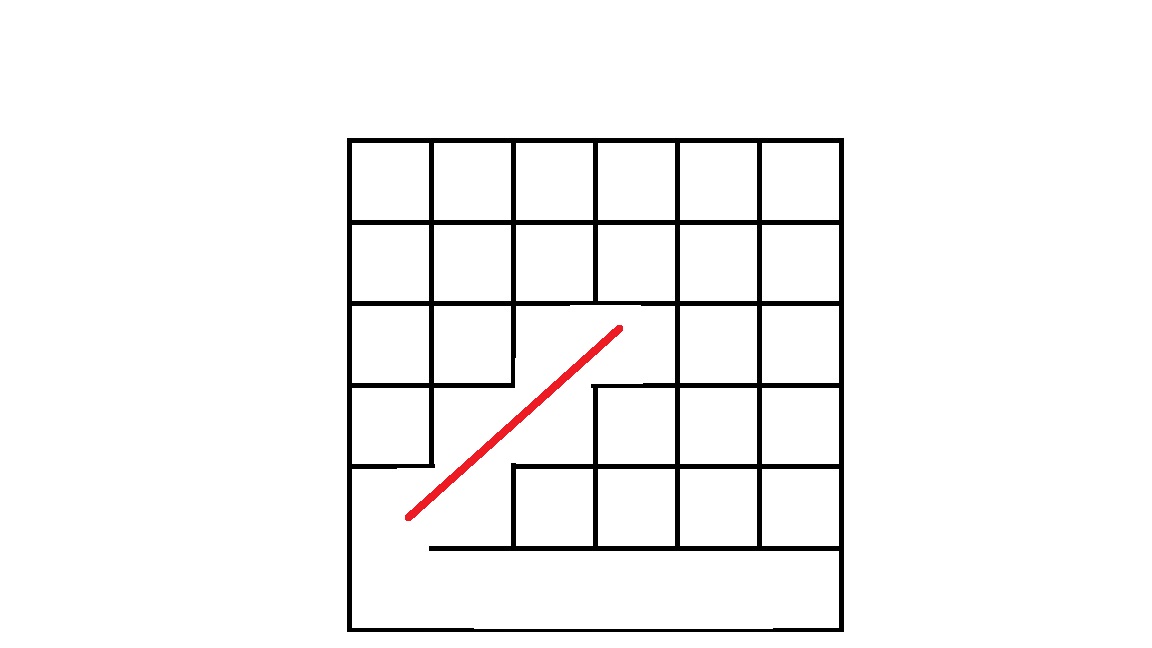
On 11th September 2026 we decided to start some diagonal work.
We are using R4D4, a maze solver, which might be a bit wide for diagonal works, but we said we would try it.
The task can be broken down in a number of steps.
STEP1
Just see if the robot can do a simple run along a diagonal
We did this without steering, just making it go straight,
and starting it in the right position.
We adjusted the motor speeds (PWM) to get it to go straight,
and it worked out that the same PWM was good enough.-
STEP 2
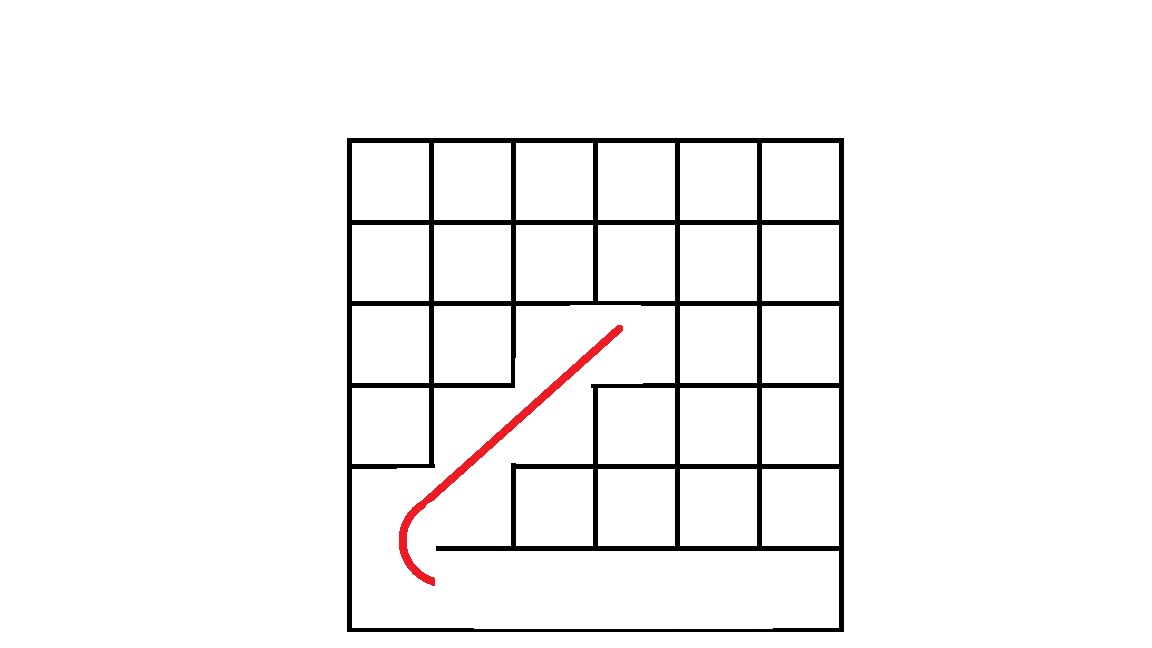
Make it do a 135 degree right turn, with the correct inner radius that means it could
start in the bottom horizontal track of the maze:
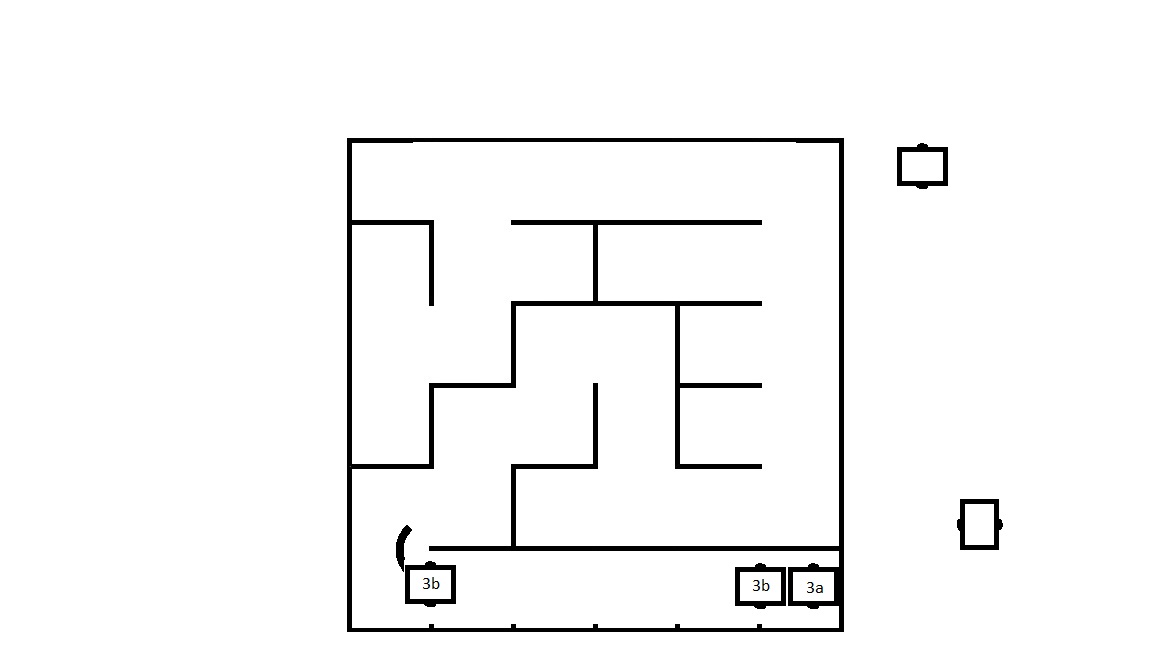
Step 3
3a Make robot go forward until the wheels are at the very start of the next cell after start
go straight forward, distance according to encoders
3b Move forward 4 cells exactly to be in the correct position for step2
it should steer to be exactly in the centre of the path
it should detect right wall disappearing to correct any inaccuracies in the distance
It can now be started at the start of the maze.
Further work...
- How to avoid the walls in a diagonal straight
it could do a little sideways shimmy (while still going in the same direction)
after seeing a side sensor going above a limit
- Make the robot slightly slimmer??
-Get 2 more front-facing sensors to help with wall avoidance..
By shimmy, I mean making one motor faster for a short time (250 ms),
then the other motor faster (same amount, same time)
Software improvement.
How about a function that goes forward by a given number of millimeters.
- it would require a parameter for the distance
- and a parameter on whether to steer or not.
- and a param. to say whether to stop when a wall disappears.
An extra tuning data item is needed for how many encoder pulses per mm.
More later as we progress...